
Autonomy comes from the Greek autós (self) and nómos (law). It is the capacity to act by a rule carried within. It does not wait for instruction from outside.
A machine is autonomous when it senses its environment. It compares what it finds with a goal. It corrects its own action through feedback. Autonomy in this sense means obeying a law alone. It does not mean freedom from law.
Norbert Wiener, Cybernetics: Or Control and Communication in the Animal and the Machine, 1948
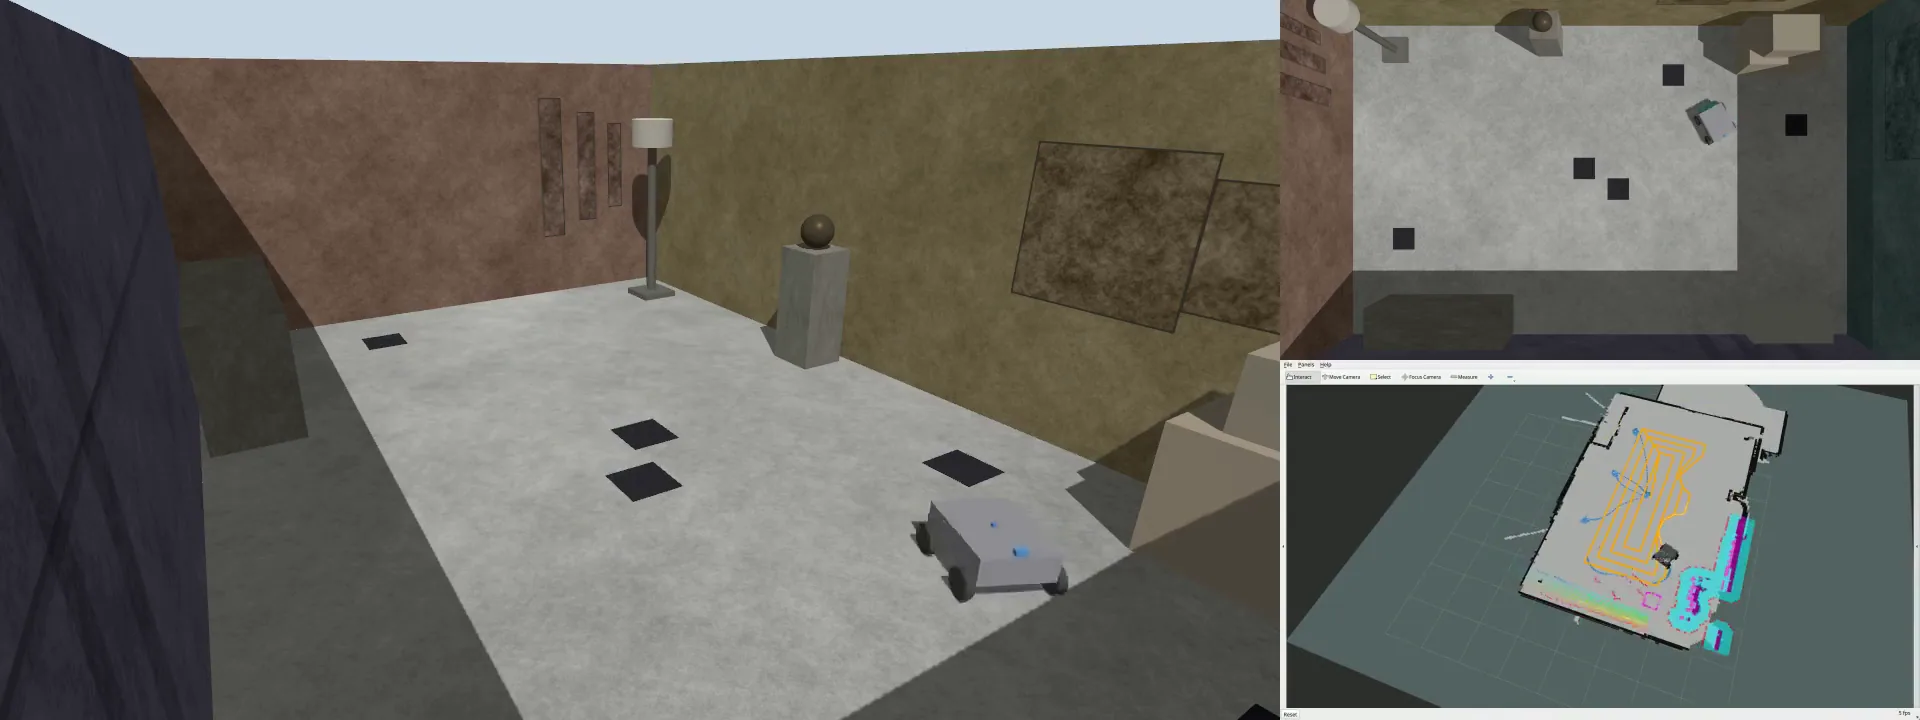
A robot is placed inside an unknown museum room. The floor consists of glass. Black liquid ink is poured onto the floor. The autonomous rover tries to find the ink patches and gather the spilled ink into the centre of the room.
The rover localizes and navigates with basic perception techniques used in robotics and autonomous systems around the world. It carries four low-power sensors: wheel encoders, an IMU, a camera and a 2D laser scanner.
The idea behind this project is Can’t Help Myself, a kinetic sculpture by Sun Yuan and Peng Yu from 2016. In that work a robot tries to sweep a dark red liquid back to the centre. Over time, as the red fluid smears across the glass and floor, the machine’s movements appear heavier and more strained, symbolizing burnout and survival.
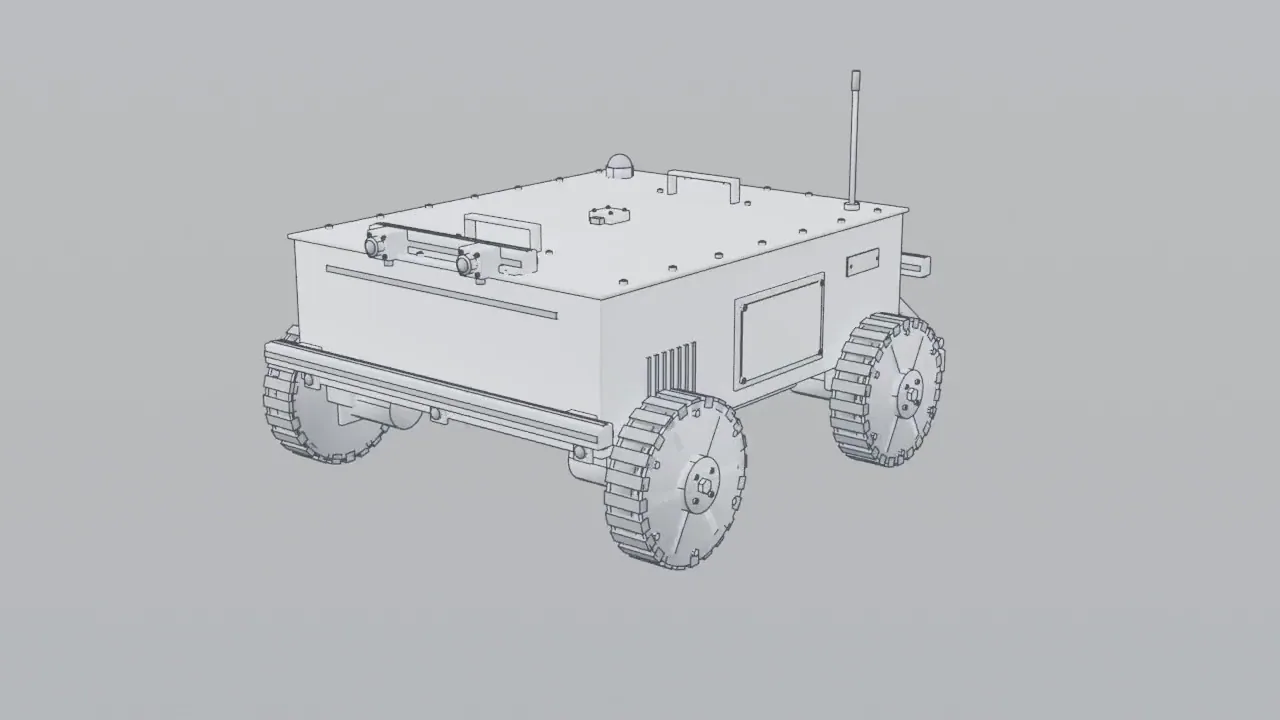
It combines the data from these sensors in real time. A sensor fusion technique with an extended Kalman filter (EKF) is used. A method called VSLAM lets it localize itself and map its position in 3D space. It explores the room and its features and finds its way around, locating the ink patches. A behaviour tree then drives it to collect the ink and push it toward the centre. It constantly works until every patch on the map is close to the centre of the room.
The whole project is simulated. It was completed after months of training with frontier navigation and perception. This is true autonomy above 90%, where a robot achieves a task without choreography or planned input.
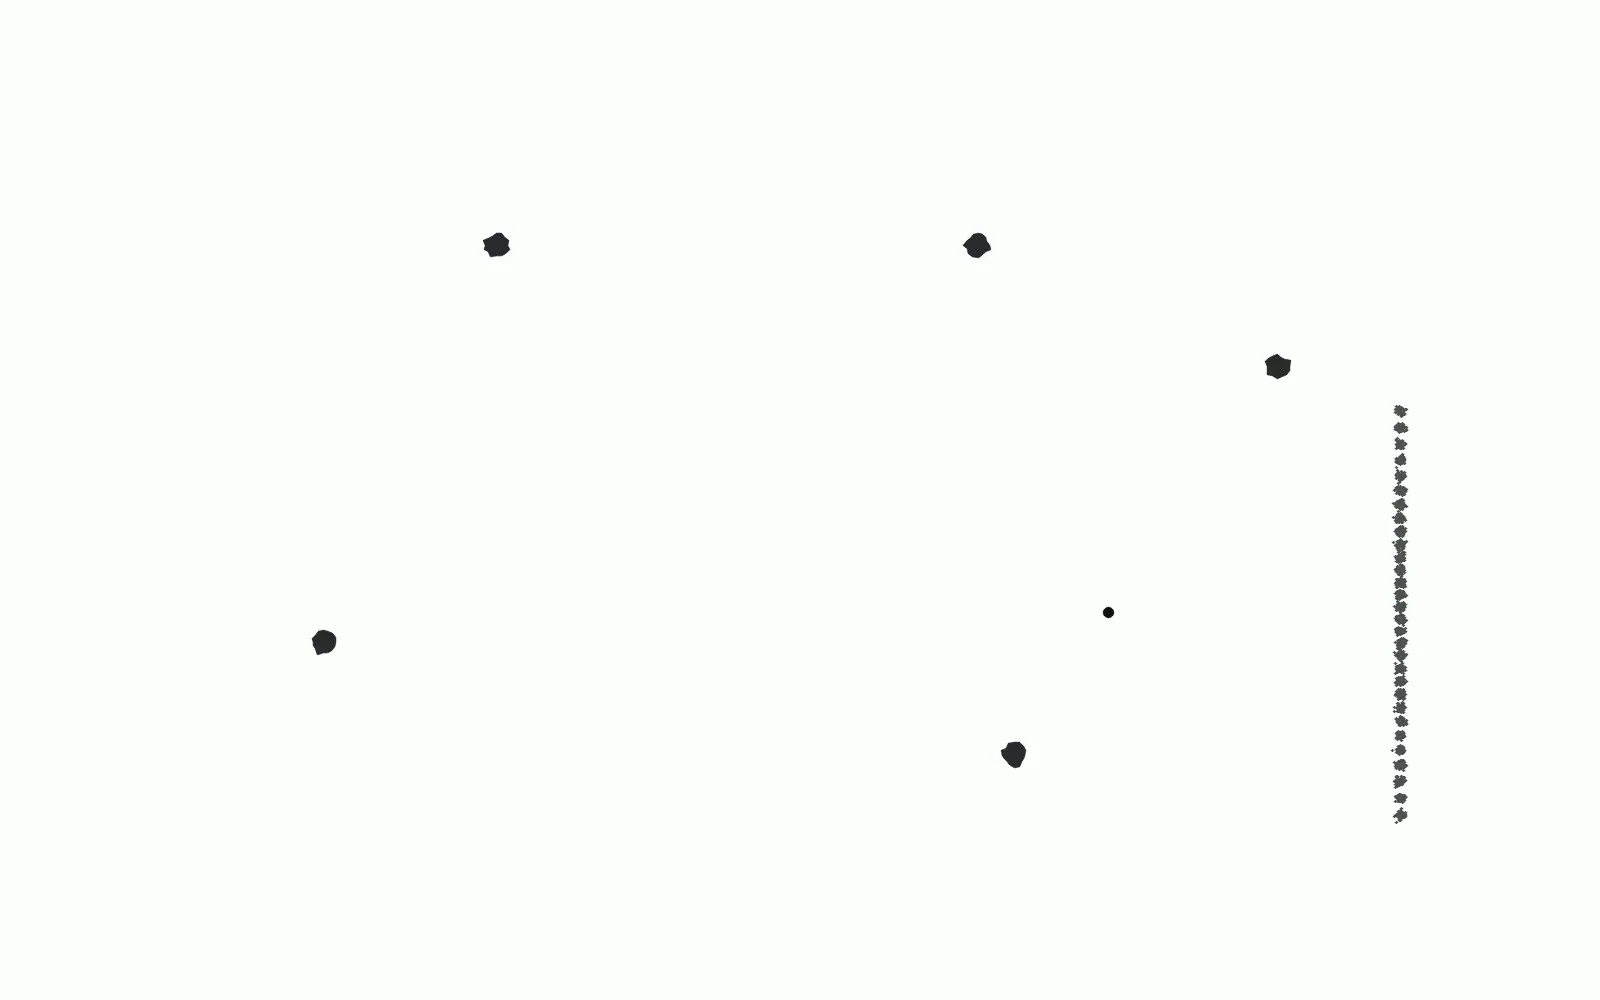
What matters in this action is exploration. The robot finds its way through the unknown. It has no clue to start from. It moves from corner to corner. It learns the world around it. It uses what it can do to complete the task.